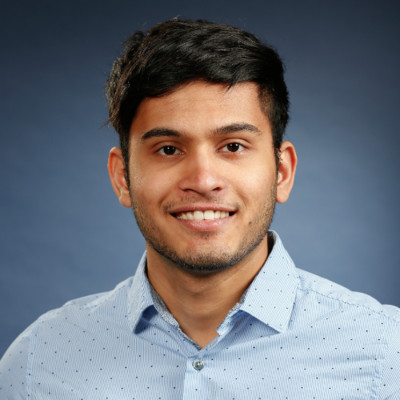
Heramb Nemlekar
Assistant Professor at California State University, Northridge
Los Angeles, California, United States


Summary
👤
Senior🎓
Top SchoolHeramb Nemlekar is an Assistant Professor and robotics researcher with eight years of experience at the intersection of robot learning, human-robot interaction, and machine learning. He holds a PhD in Computer Science from USC and has translated academic research into real-world systems—from deploying multi-objective planners on Kinova arms to running human-robot studies with over 100 participants. His work blends algorithmic advances (imitation and transfer learning) with practical system-building and user studies, enabling robots that better anticipate and adapt to human preferences. Prior roles include postdoctoral research at Virginia Tech and hands-on mechatronics projects at Worcester Polytechnic Institute, reflecting strong cross-disciplinary fluency in mechanical and software engineering. Based in Los Angeles, he is driven by making robots seamlessly helpful in daily life and has a track record of improving both performance and user-centered transfer in complex assembly and manipulation tasks.
 8 years of coding experience
 4 years of employment as a software developer
 Doctor of Philosophy - PhD, Computer Science, Doctor of Philosophy - PhD, Computer Science at University of Southern CaliforniaMaster of Science - MS, Mechatronics, Robotics, and Automation Engineering, 4.0 / 4.0, Master of Science - MS, Mechatronics, Robotics, and Automation Engineering, 4.0 / 4.0 at Worcester Polytechnic InstituteSavitribai Phule Pune University
 English, German, Hindi, Marathi

Github Skills (27)
inverse9
entropy9
causal8
robot-control7
python7
motion-planning6
ros6
ada6
machine-learning6
robotics6
programming-language6
dynamics5
reinforcement-learning5
simulation5
kinematics4
Programming languages (4)
Github contributions (5)
hsnemlekar/inverse-reinforcement-learning
Feb 2021 - Dec 2022
Maximum Entropy and Maximum Causal Entropy Inverse Reinforcement Learning Implementation in Python
Contributions:2 PRs, 65 pushes, 3 branches in 1 year 10 months
maximumentropypythonreinforcement-learningcausal
herambnemlekar/herambnemlekar.github.io
Dec 2020 - Feb 2025
Contributions:77 pushes, 1 branch in 4 years 2 months
Find and Hire Top DevelopersWe’ve analyzed the programming source code of over 60 million software developers on GitHub and scored them by 50,000 skills. Sign-up on Prog,AI to search for software developers.