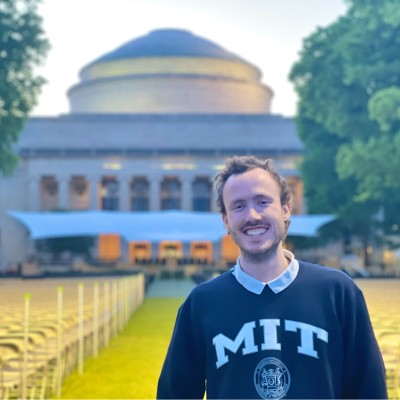
Odin Severinsen
Robotics Software Engineer at KEF Robotics
Oslo, Norway


Summary
👤
Senior🎓
Top SchoolOdin Severinsen is a robotics software engineer in Oslo with eight years of hands-on experience building autonomy and estimation systems for real-world platforms. He has practical expertise in ROS, sensor fusion, error-state Kalman filters, PCB hardware/software debugging, and CI-driven Git workflows, and has applied these skills to autonomous ferries and research projects. Comfortable leading interdisciplinary teams, Odin has held technical leadership roles in high-tempo settings—from chief electrical engineer for a student racing program to managing software projects at KEF Robotics. He pairs academic depth (Master’s in Cybernetics and Robotics, studies at MIT) with teaching experience across robotic vision, sensor fusion, control and statistics courses at NTNU. Known for sustained productivity under pressure, he blends rigorous estimation algorithm implementation with pragmatic systems integration. An interesting detail: beyond software he has led battery and housing design for a race car, giving him rare cross-domain insight into both mechanical and autonomy stacks.
 9 years of coding experience
 3 years of employment as a software developer
 Norges teknisk-naturvitenskapelige universitetNon-degree, Advanced Study Program, Non-degree, Advanced Study Program at Massachusetts Institute of Technology

Stackoverflow
23reputation
178reached
0answers
1question

Github Skills (13)
semi-supervised-learning9
slam8
generics6
iterator6
rust6
pose-estimation4
ros2
machine-learning2
reinforcement-learning2
deep-learning2
codebase2
deep-reinforcement-learning2
pytorch2
Programming languages (5)
Github contributions (5)
odinase/da_slam
Feb 2022 - Feb 2024
Contributions:85 pushes, 24 branches in 2 years
odinase/ttk4130_modeling_and_simulation
Jan 2020 - May 2020
Contributions:11 commits, 10 pushes, 1 branch in 4 months
Find and Hire Top DevelopersWe’ve analyzed the programming source code of over 60 million software developers on GitHub and scored them by 50,000 skills. Sign-up on Prog,AI to search for software developers.